
EQUIPMENT
Palletizing robots for insulation products
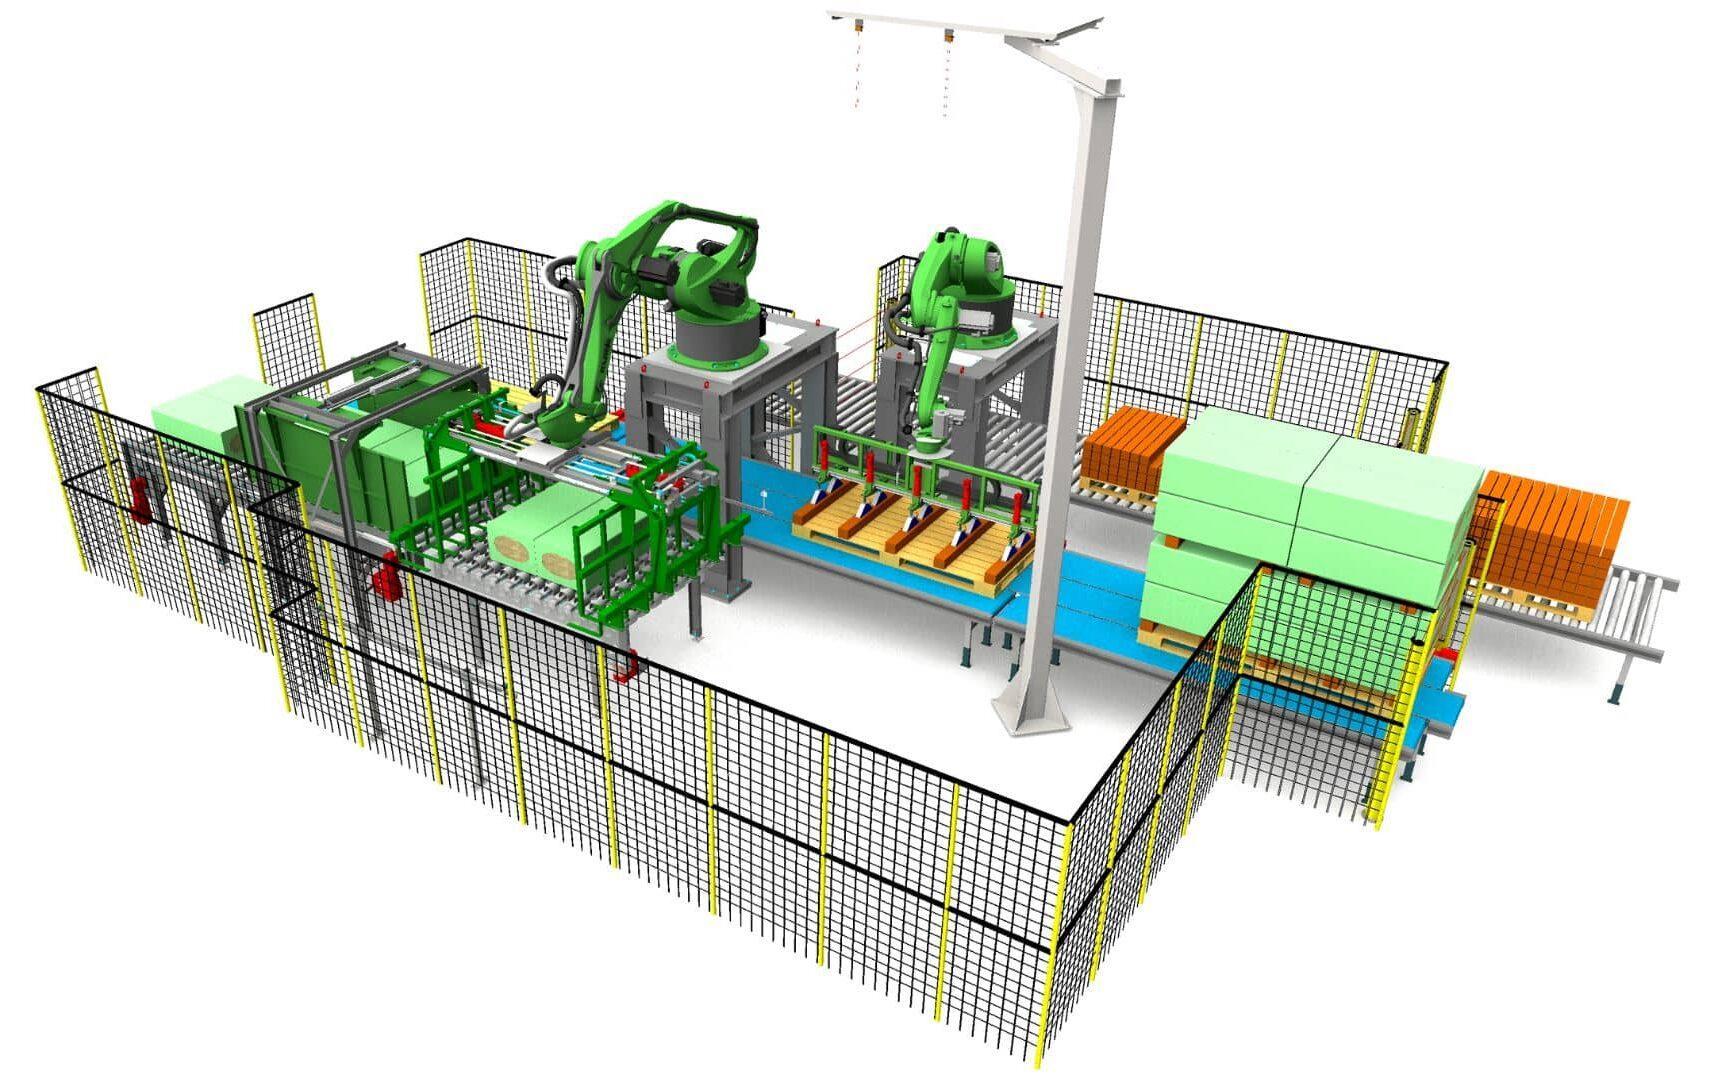
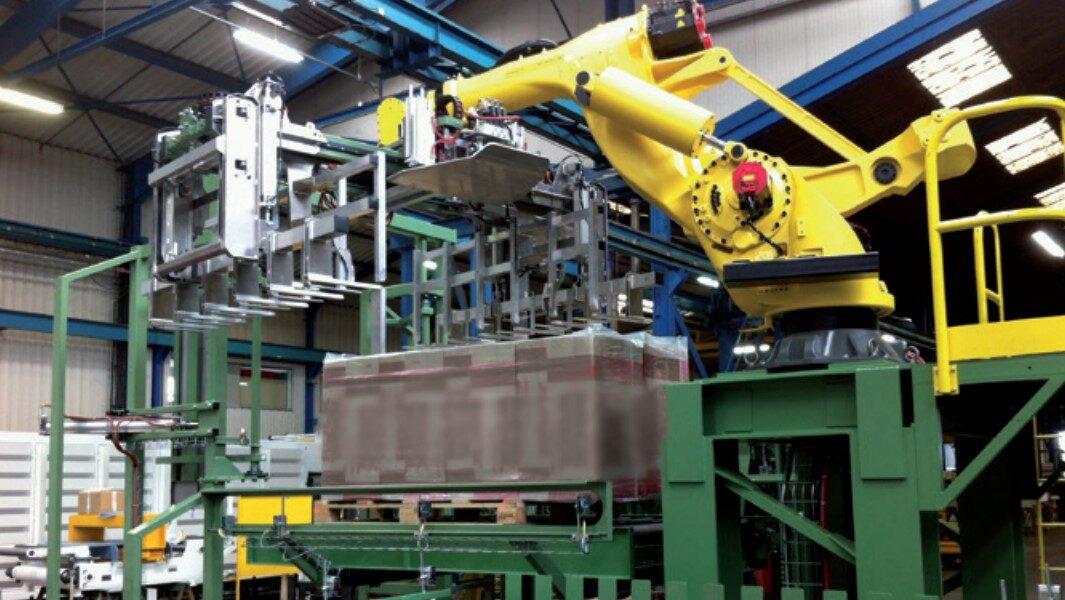
The palletising robot builds loads from insulation packs at the end of the line. FIMEC SH designs the gripper, placement patterns and supports around the required formats, including palletless arrangements using insulation supports.
Products
Insulation boards and packs
Gripping
Multifunction gripper designed for the required formats
Supports
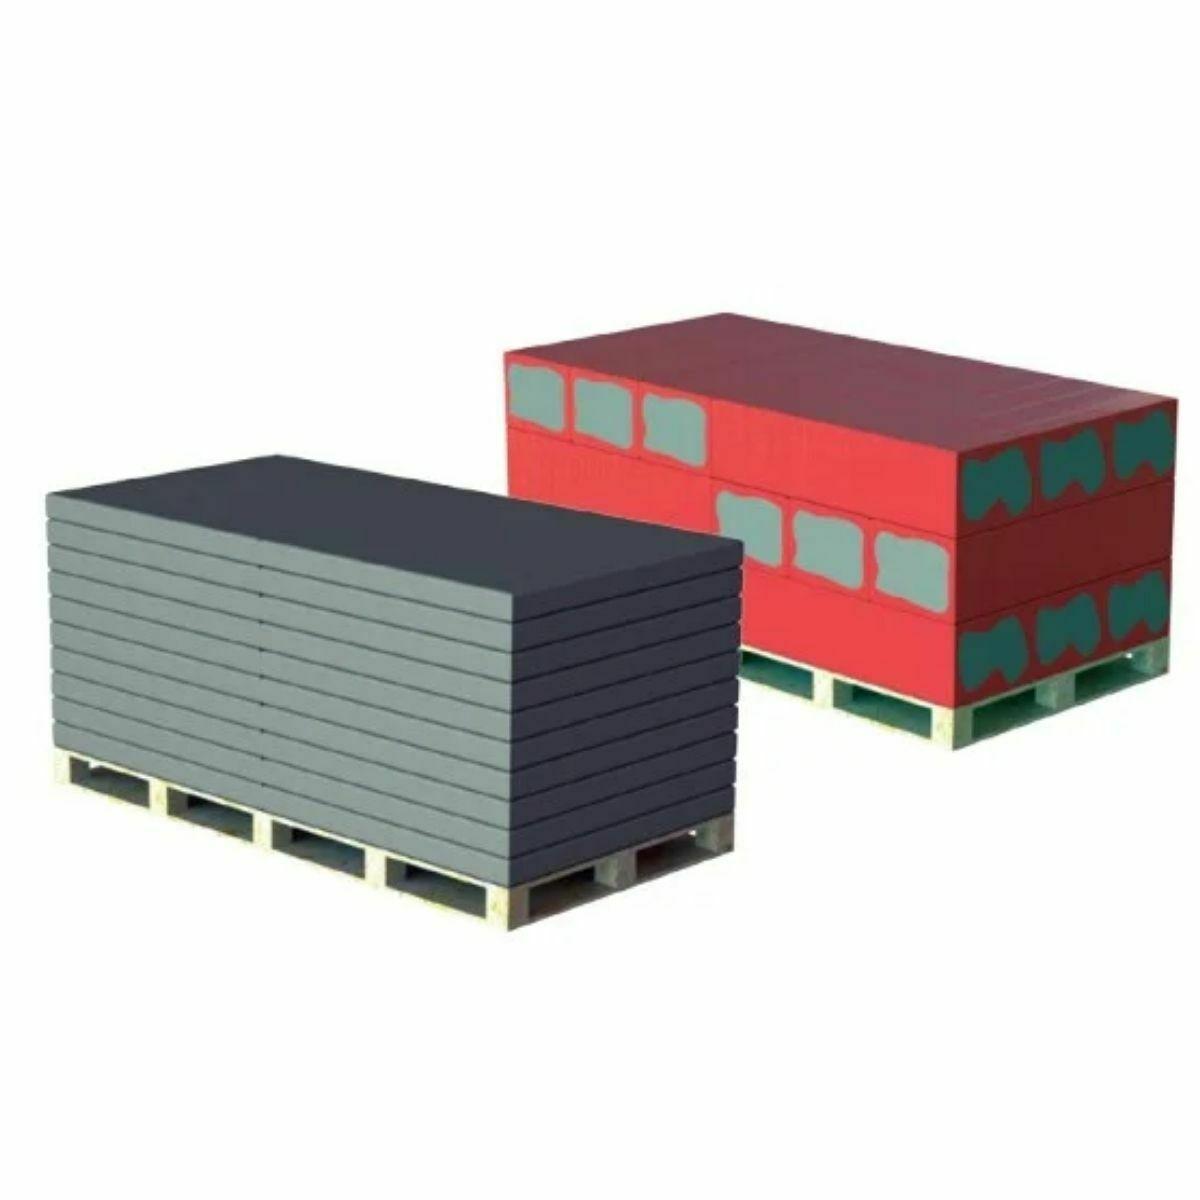
Pallets, long multiple-pallet arrangements or insulation supports
Placement
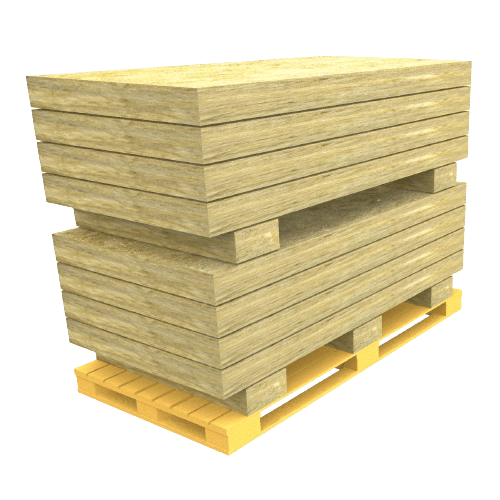
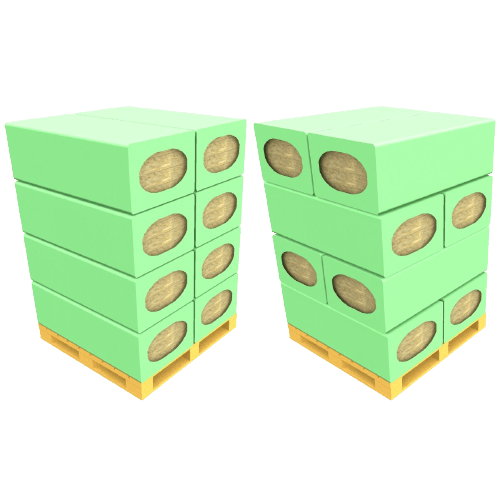
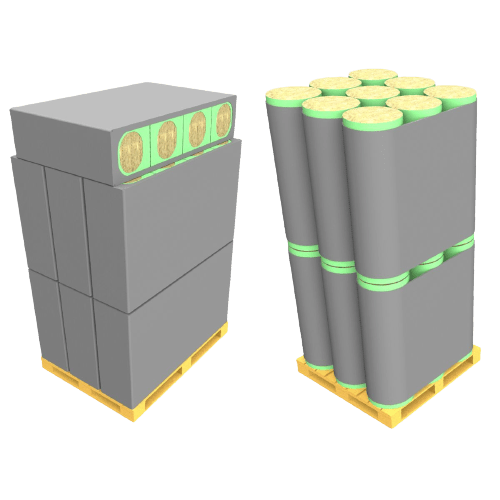
Horizontal, vertical or crossed packs
Width
Insulation palletising example: 0.8 to 1.3 m
How it works
A multifunction gripper handles the specified formats without a tool change. Packs can be placed horizontally, vertically or in crossed layers. The robot can form part of a line that includes pack centering, turning and gluing. Engineering distinguishes robot cycle time from the pack throughput achieved with each palletising pattern.
Key features
Length
Insulation palletising example: 1 to 3 m
Load height
Specified against the palletising pattern and handling requirements
Cycle rate
Insulation palletising example: up to 5.5 cycles/min
Throughput
Determined by the number of packs handled per cycle and the stacking pattern
Changeover
No gripper change for the specified formats
Preparation
Upstream centering, turning and adhesive application, depending on the line
The multifunction gripper picks packs in the formats specified for production. The programme places them horizontally, vertically or in crossed layers.
Supports can be pallets, long multi-pallet arrangements or skids made from the same insulation as the product. The latter can be reused on the construction site.
Throughput depends on packs handled per cycle, their orientation and the placement pattern. Robot cycle rate alone therefore does not define final throughput.
- Pack dimensions and stability.
- Support and completed load dimensions.
- Layer arrangement and production changes.
- Arrival rate and load discharge.
The pick-up position receives packs after preparation. Centring, turning and gluing belong to upstream stations; the robot then performs pick-up and placement.
Gripper selection takes account of all specified formats. The complete support and transfer arrangement is described in the palletising solution.
Used in these solutions
Production lines for mineral wool insulation boards
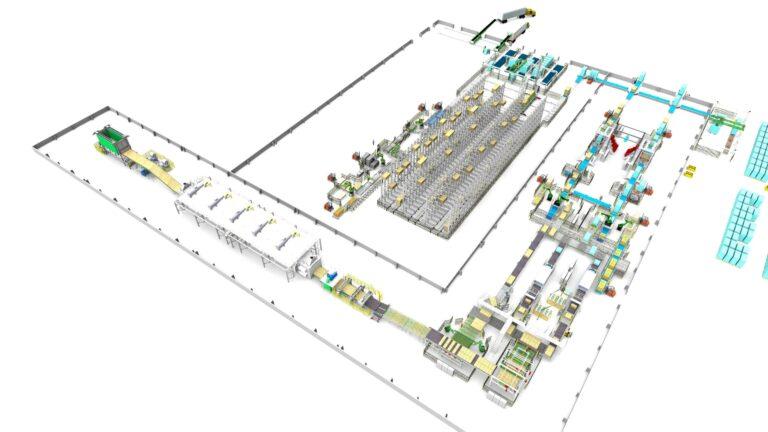
After fibre production, the mineral wool line turns fibres into boards ready for dispatch. FIMEC SH provides equipment for collection, forming, curing, cutting and packaging.
Automated palletizing systems
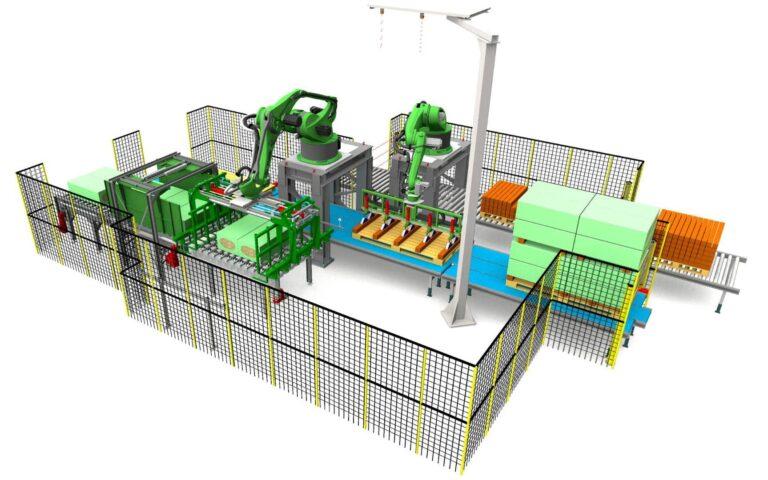
Automated palletising builds loads at the end of production. For insulation products, it combines pack preparation, gripping and placement on pallets or insulation skids to suit the required packaging.