
SOLUTION
Custom multifunction robotic cells
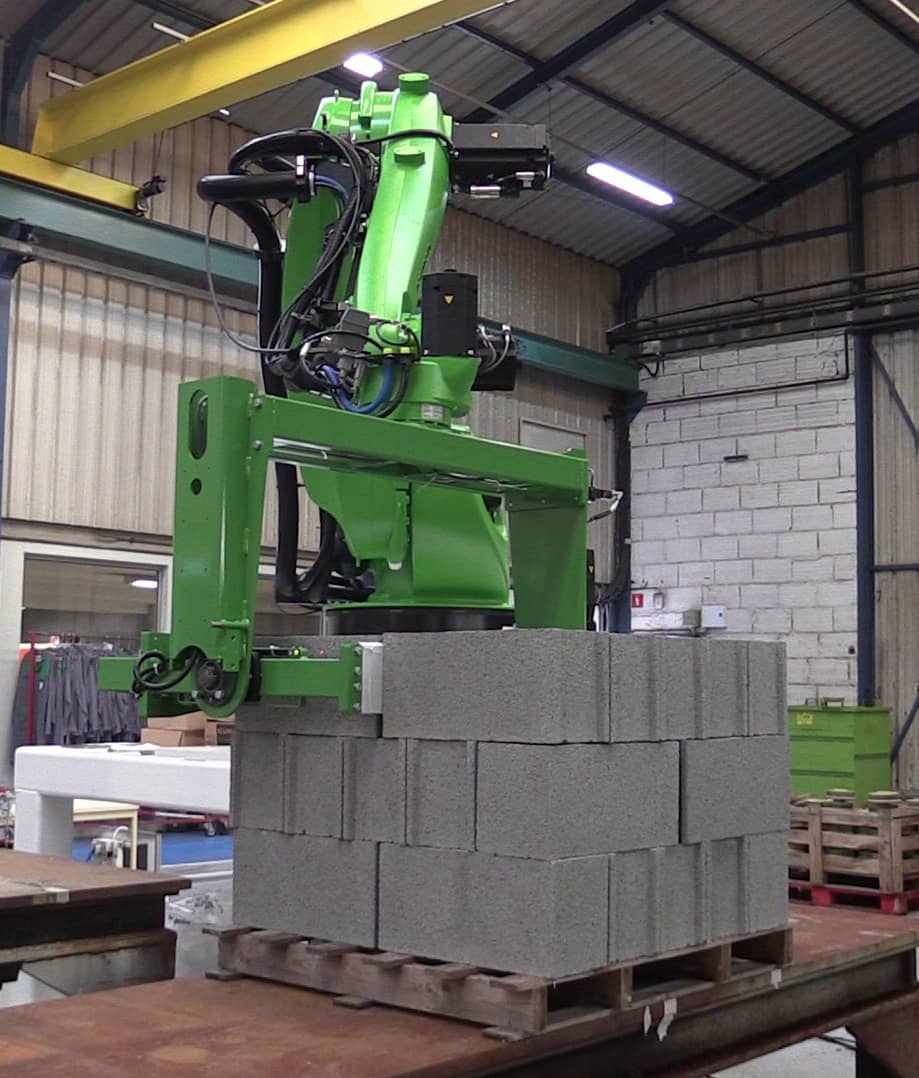
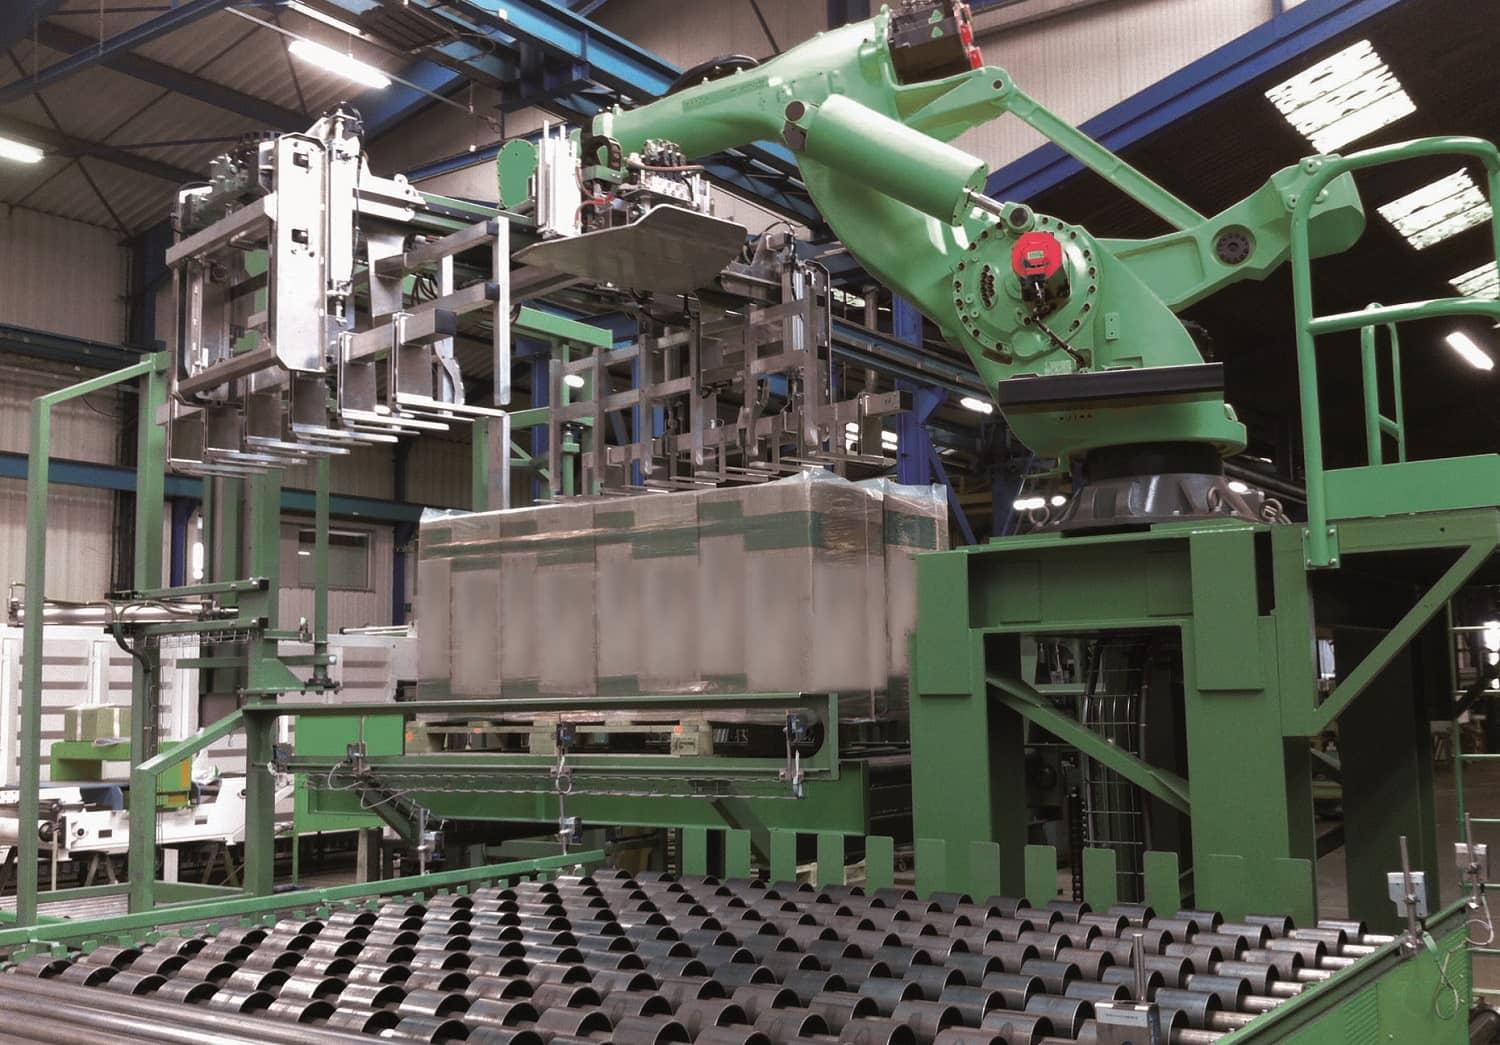
A robotic cell combines several handling operations around multi-axis robots. FIMEC SH designs grippers for the products and integrates the cell with manufacturing, inspection or palletising stations.
Architecture
Multi-axis robots
Gripping
Multifunction grippers
Design
Custom-designed for the product
Integration
Overall process and line environment
Handled products
Grippers adapted to heavy products
Several operations in one robotic sequence
A robot’s role can extend beyond moving a part. In a finishing cell, it can unload products, feed the process, collect finished parts and palletise them. Empty carrier and rejected-product handling complete the sequence.
The multifunction gripper is designed around pick-up surfaces and the operations required. Robot integration is considered within the line, including interfaces between stations.
Line functions
Process changes
Possible reassignment of robots
Control
Simplified user interfaces
Operation
Multifunction robotic units
The robot can handle products and their associated items: boards, pallets and timber spacers. The gripper must support the specified operations; one tool is not assumed to suit every product.
Operator interfaces provide access to cell controls and the information needed to run it.
The study considers upstream and downstream stations, production carriers and transfer areas. When a process changes, reuse of an existing robot can be assessed against its capacity and the new movements required.
- Unloading production boards and feeding the finishing unit.
- Identification and removal of non-conforming products.
- Collection after finishing and removal of empty boards.
- Pallet changes, product placement and spacer insertion.
An ALFI Technologies installation for SOTUBEMA applied this approach to concrete kerbs. It illustrates the combination of several functions within one cell.